Four legs, hand-tuned
Every leg got fitted and adjusted over and over until the walk stopped looking like a machine and started looking like a little creature.
HANDMADE BY EBEN SIYABALAPITIYA
A little robot spider I designed, printed and wired myself. Momo walks, makes faces, and has cost me two Raspberry Pis so far. Built over a lot of late evenings, one problem at a time.
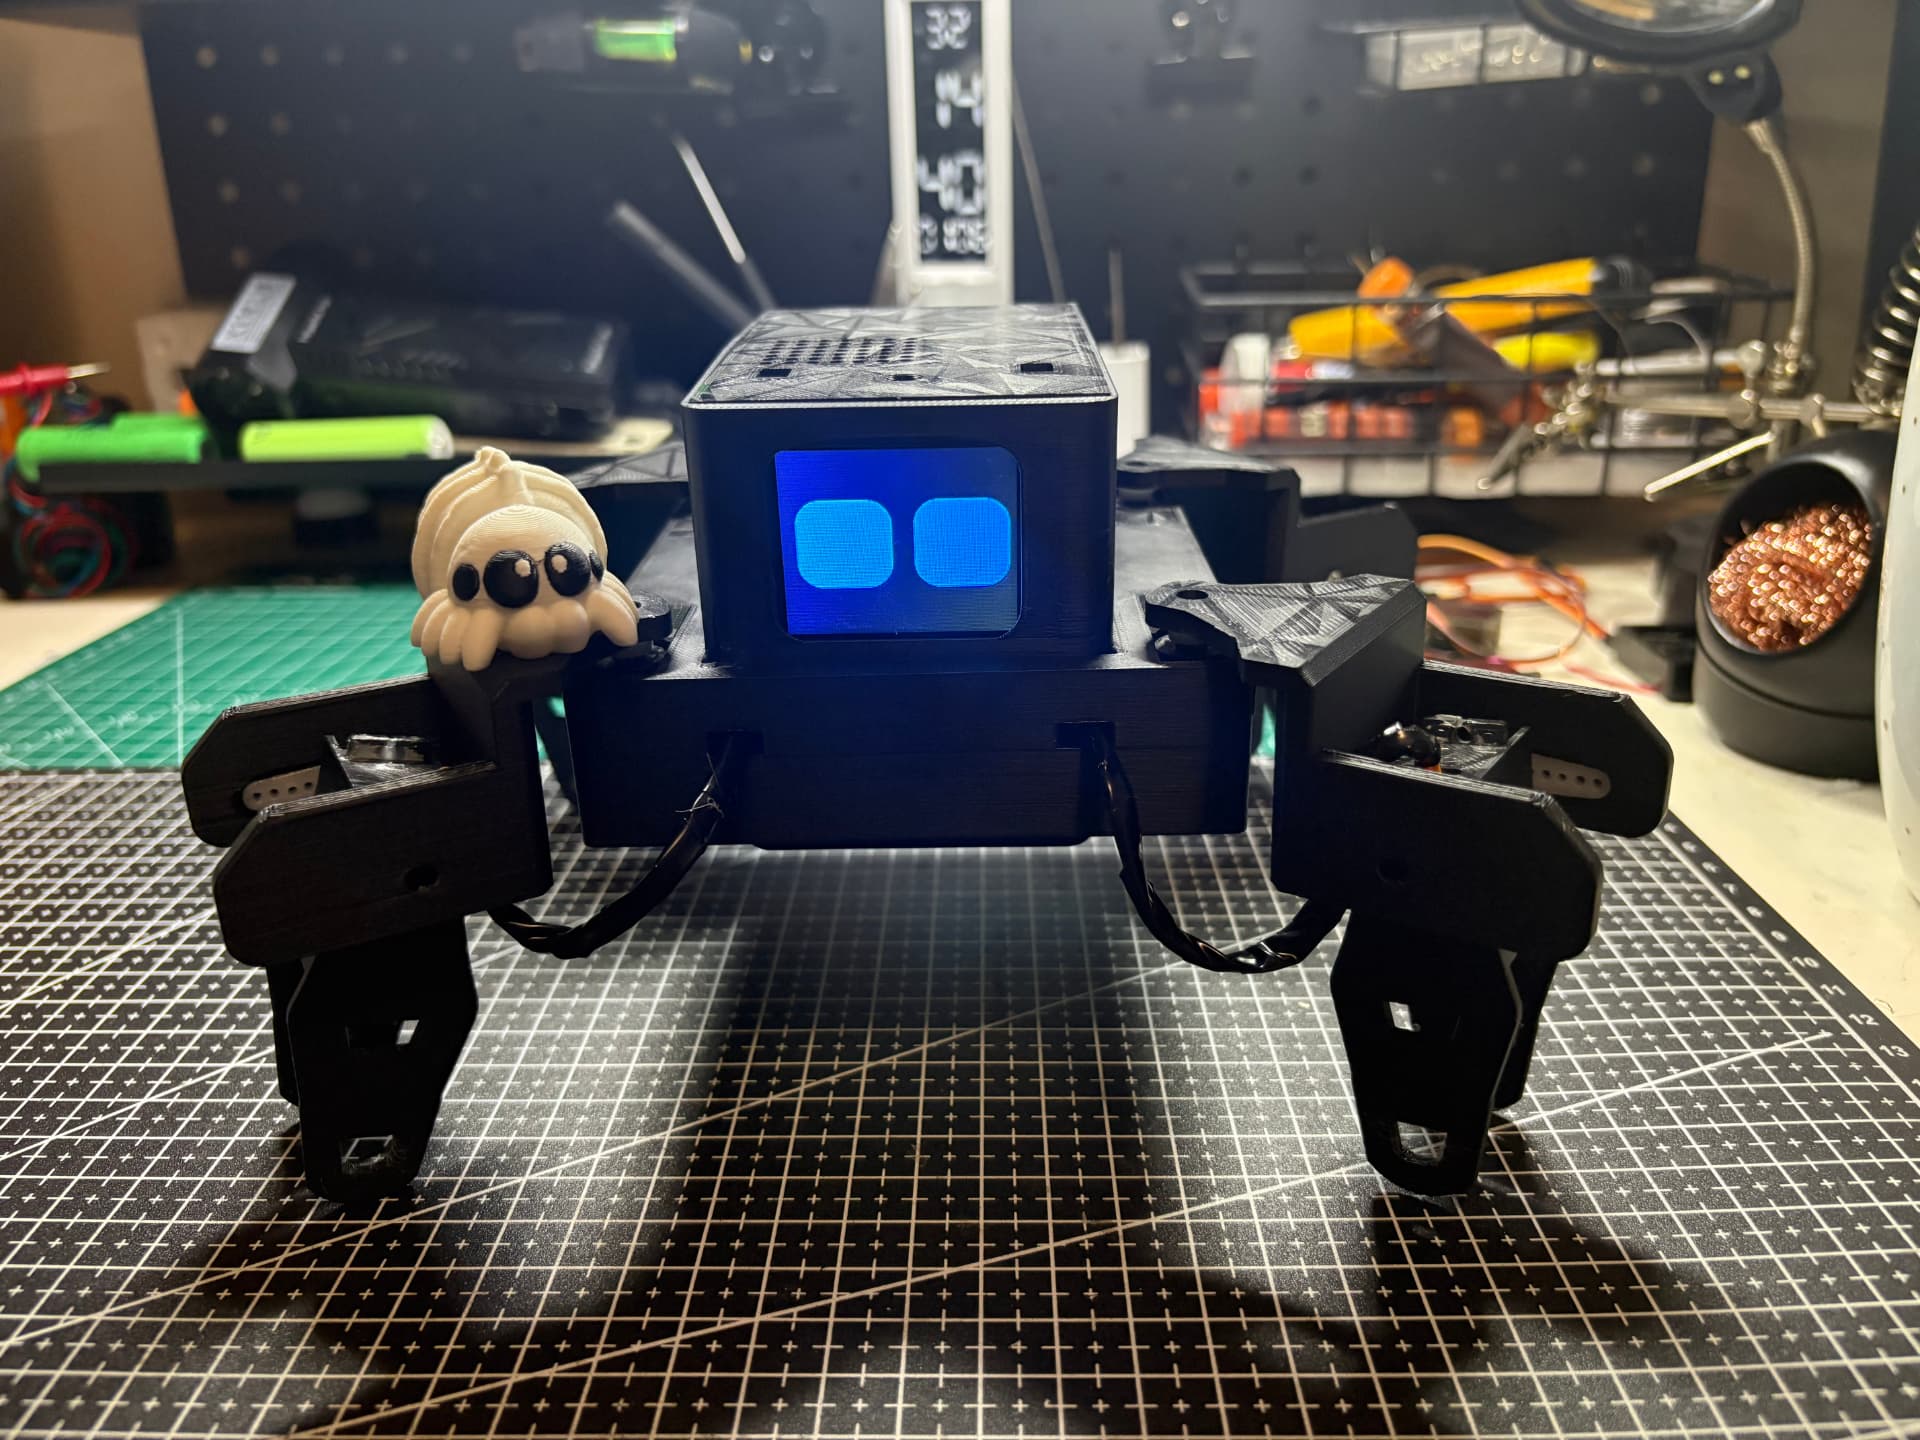
Every leg got fitted and adjusted over and over until the walk stopped looking like a machine and started looking like a little creature.
No factory, no production run. Just a desk, a soldering iron, and a lot of evenings that ended worse than they started.
Rounded shell, slow movement, nothing sharp. He's a spider you'd actually let walk across your desk, and hopefully not fall off.
Motion
Momo walks in a trot. The legs work in diagonal pairs, one pair swings while the other pushes, so two feet are always on the floor. Each step phase takes about a fifth of a second. He can also walk backwards, turn, sit, wave, dance and hold a pose for photos.
Every servo got its home angle calibrated by hand through the web panel, because no two of them sit in the frame exactly the same way.
At a glance
What Momo is actually made of.
In action
Momo listens and answers back. A greeting, a sit, then a little pause while he works out what you asked. Sound is off by default, so tap the speaker to hear him.
Life with Momo
Sometimes he chases the cat. Sometimes he just talks back. These are the little moments that make Momo feel less like a machine and more like himself.
Momo chases him down, then celebrates with an emote.
A regular conversation, followed by the response he decided was right.
The maker
Momo is a solo project. I designed him, built him, wired him and wrote every line of code myself, at a desk in my room. Took months, two dead Raspberry Pis and more failed leg prints than I want to count. I kept going because I wanted to see him walk.